WARL: Wrench-Augmented Reinforcement Learning for Task-Agnostic Learning in Legged Robots
Proceedings of the 2026 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2026

Master's student
JSK Robotics Laboratory · The University of Tokyo
From mechanism to learning — building quadruped robots that keep getting better out in the real world.
I work across the whole stack of a legged robot — designing the mechanism, writing the software that drives it, and integrating the two into a machine that leaves the bench — with machine learning as my specialty. My recent work centres on KLEIYN, a quadruped with an active waist joint that walks, climbs chimneys and stands up on two legs. I am currently most interested in giving robots new sensing modalities, in continual learning that lets them keep growing after deployment, and in putting quadrupeds to work in the real world.
Proceedings of the 2026 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2026
IEEE Robotics and Automation Letters (RA-L), 2026
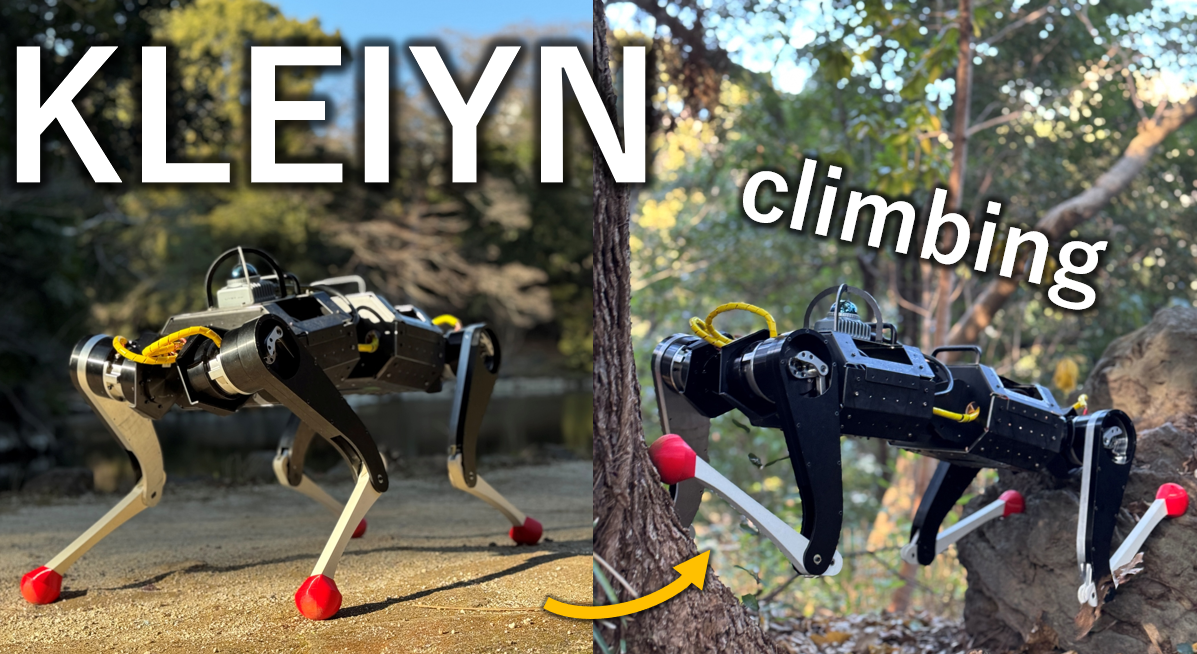
Proceedings of the 2025 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2025
IEEE Robotics and Automation Society Japan Joint Chapter Young Award
for “KLEIYN: A Quadruped Robot with an Active Waist for Both Locomotion and Wall Climbing”
Workshop on Climbing Robotics Best Early-Career Talk Award
for “Chimney Climbing of Quadruped Robot KLEIYN With Active Waist Joint Based on Contact-Guided Curriculum Learning”